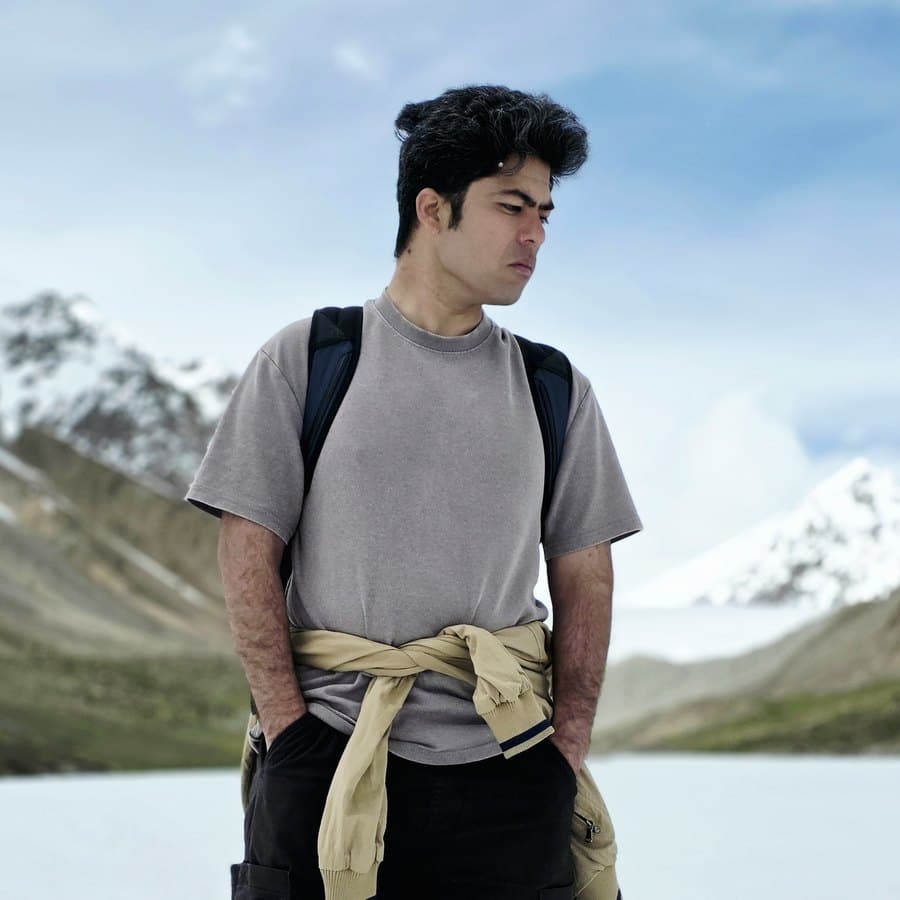
Me, standing in the snow with mountains behind

Hi, I'm issam.

I'm a software engineer from Mardan, Pakistan. I studied computer science at GIKI and graduated in 2024. Since then I've worked remotely for a software team in the Netherlands, building backends, web apps and smart contracts.

I make my games in Godot, under the name Meloo Interactive. Meloo means bear where I come from, which is why the logo is a bear.

Two kinds of work that teach each other

My day job and my games look nothing alike, but the same problems keep showing up in both.

AT WORK

Backends, web apps and smart contracts

I build Django and Express services, the React and Next.js screens people use, and a React Native wallet. I also write smart contracts for marketplaces and staking, with random reward draws that anyone can check.

WHAT THEY SHARE
Results anyone can checkAt work I built random reward draws that anyone can verify. In Fresh Powder, the server checks every sled run with the game's own code before it counts.
Django and Next.jsThe tools I use at work also run Fresh Powder's online backend and this website.
Beating the delayMy student rover had to react quickly on a tiny computer. Neon Brawlers has to hide a quarter of a second of lag.
IN MY OWN TIME

Games, mostly for phones

I make games from start to finish in Godot 4: the gameplay, the physics, the tools for making levels, the servers and the store releases. You can play three of them on this site.

How I got here

  1. Sep 2020Started computer science at GIKI
  2. Apr 2023Started freelancing: web and mobile apps for clients abroad
  3. 2023 to 2024Built a self-driving rover that came third at GIKI
  4. May 2024Joined a remote team in the Netherlands as a software engineer
  5. 2026Made six games, and put Fresh Powder and this site online
  6. NowMaking games, and writing up how they work

My CV

The short version of this site, on two pages: my games, my job, my degree and my skills.

Download CV (PDF)
May 2024 to now
Software engineer, remoteDjango and Express backends, React and Next.js front ends, and a React Native wallet with about 5,000 monthly users. Smart contracts for marketplaces, staking and bridging, including random reward draws that anyone can verify.
2026 to now
Independent game developer, Meloo InteractiveSix games in Godot 4, one in Google Play testing. Deterministic simulation, UDP netcode, a Django game backend, physics, level solvers, and Android and web releases.
Apr 2023 to May 2024
Freelance software engineerWeb and mobile apps for international clients, from requirements to deployment.
2020 to 2024
BS Computer Science, GIKIFinal-year project: a self-driving rover on a Jetson Nano with LiDAR and a camera. Third place at the GIKI Industrial Open House.

Off the clock: robots and drones

The rover never really left me. These are things I build for fun when I'm not making games. Most of them come with CAD files, print files and a simulation you can start with one command. Move your cursor overHold your finger on a picture to see inside.

  • It combined the LiDAR and camera data to see the road around it.
  • I shrank the steering model until it could run on the Nano itself.
  • I tuned the steering controller to the delay I actually measured, rather than a guess.
Final-year project · third place at GIKISelf-driving roverA rover that drove itself around campus, running on a Jetson Nano with LiDAR and a camera. Everything else here started with it.
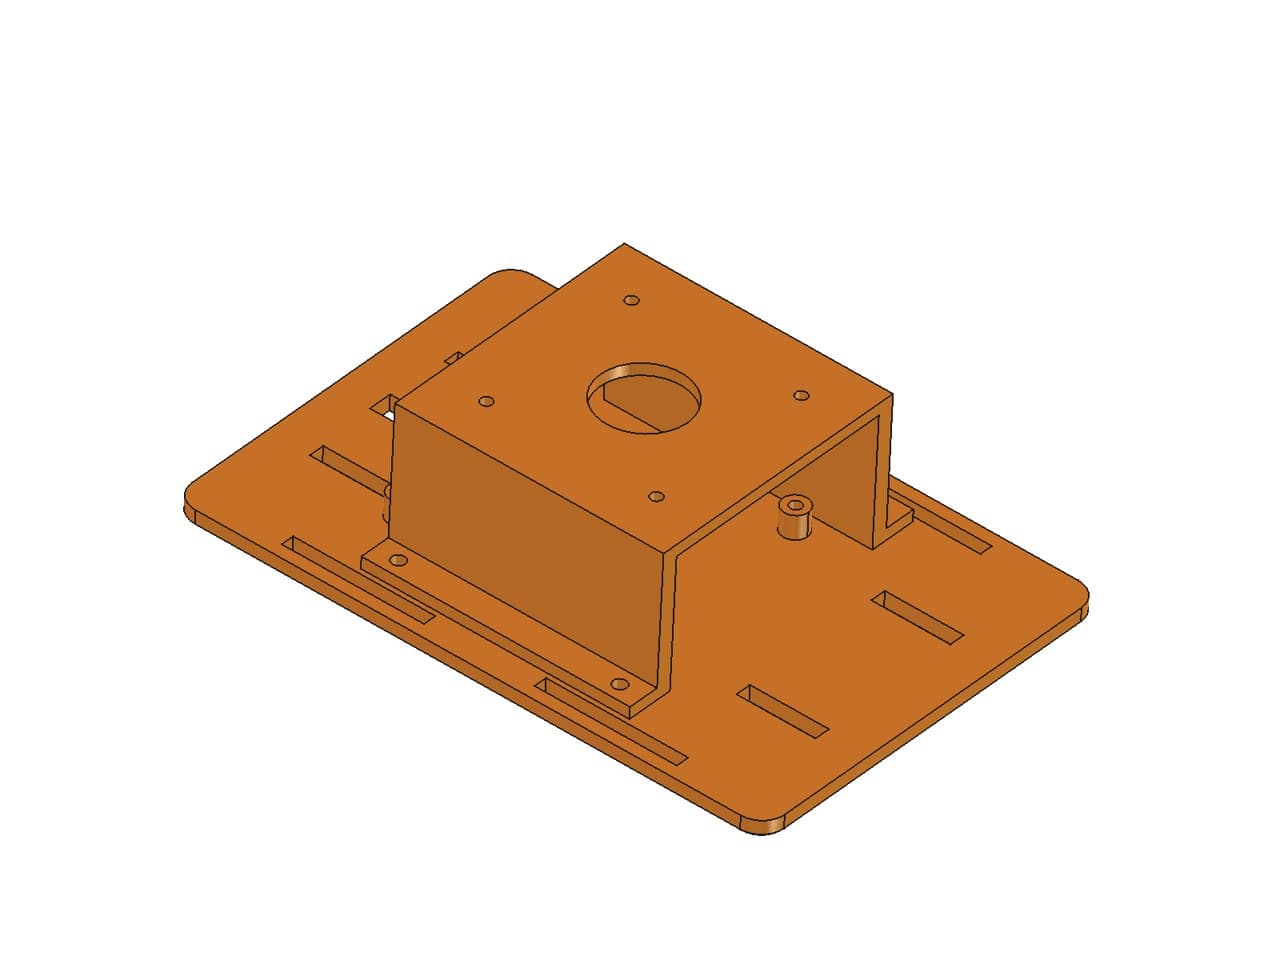
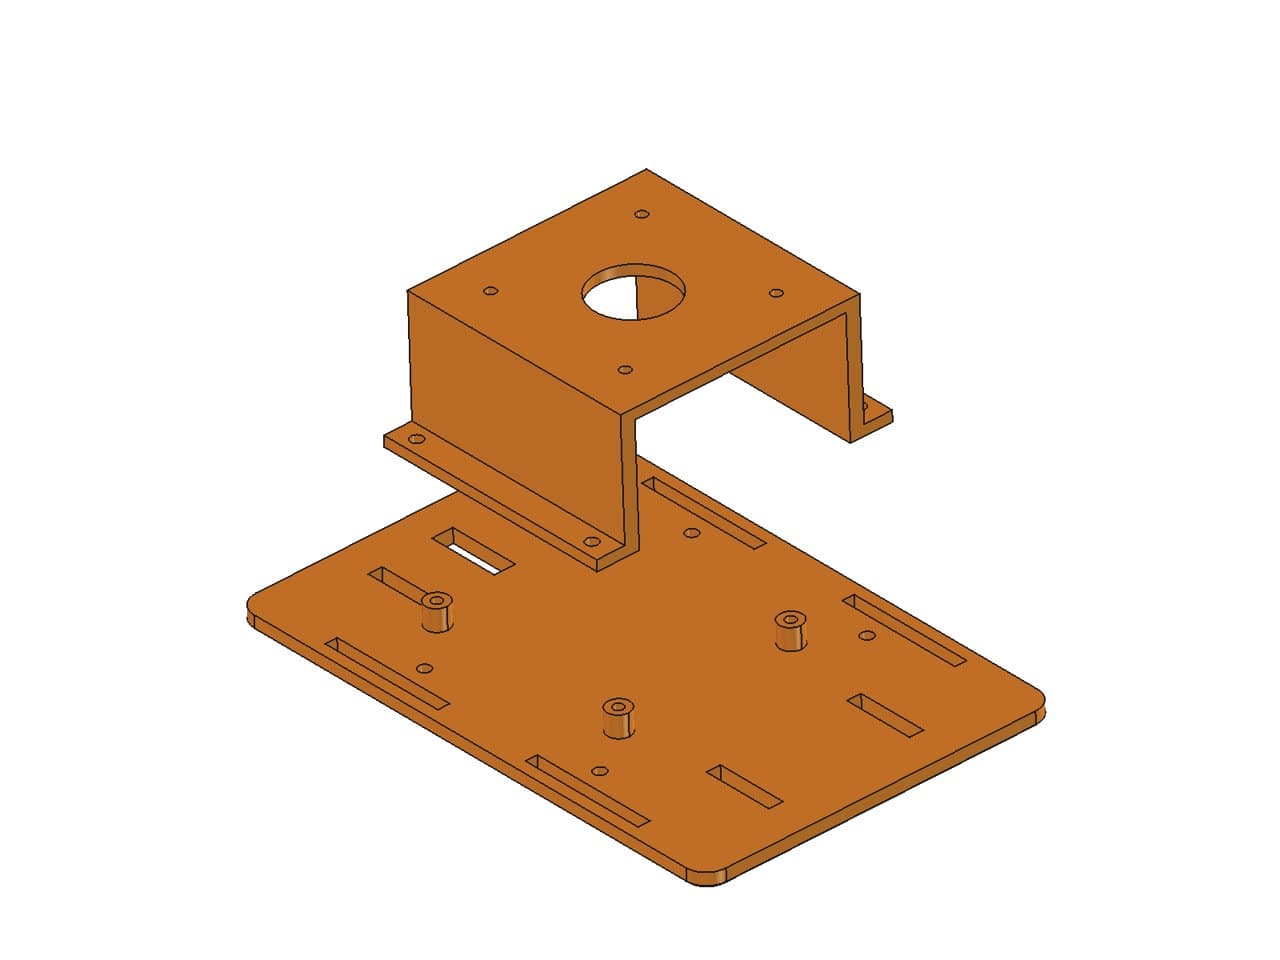
CAD render
Built and tested in simulationNav2 DeckTwo 3D-printed parts that turn a $30 chassis into a robot that finds its own way around with ROS 2. It comes with a robot model (URDF), a Gazebo world and a launch file.
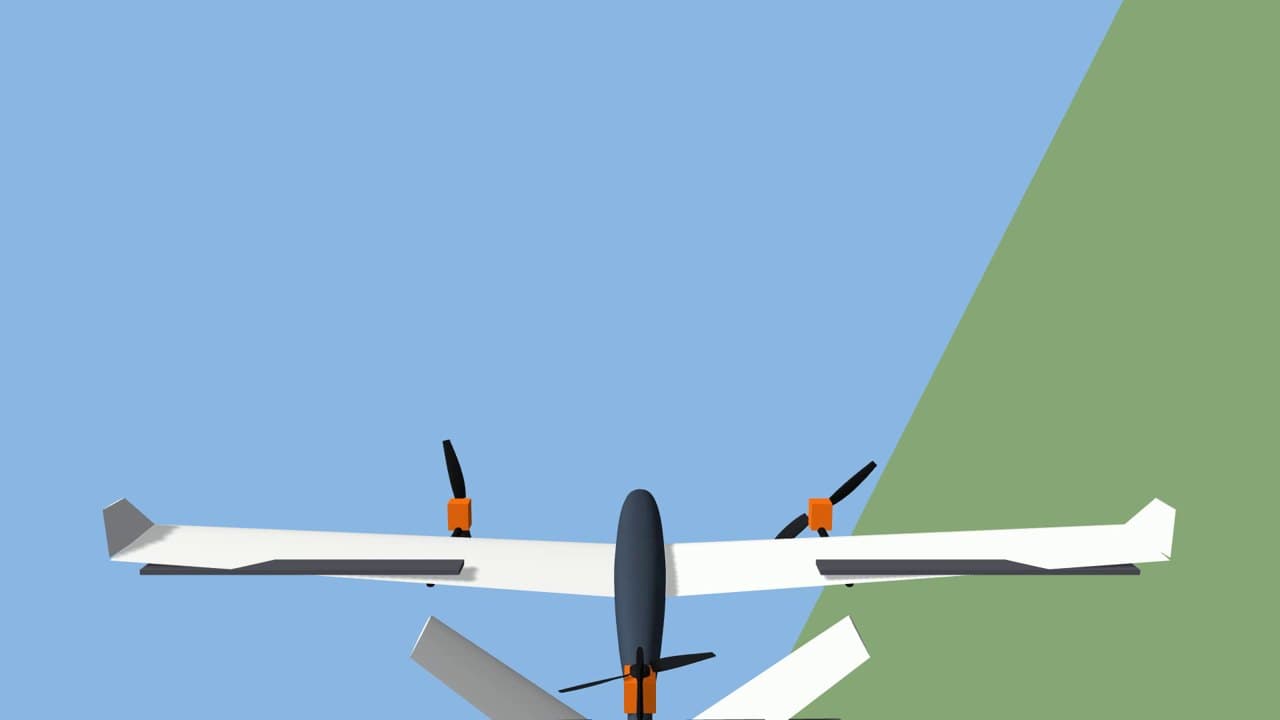
PX4 and Gazebo simulation
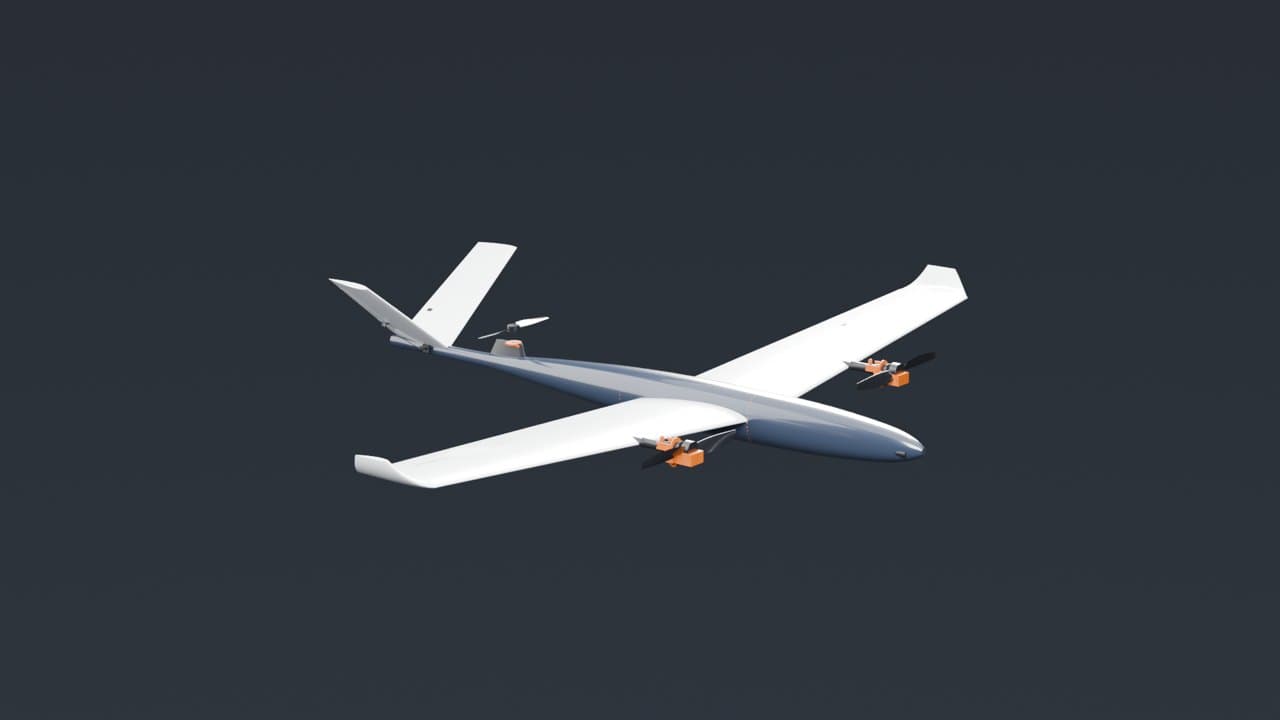
On pauseTiltrotor VTOLA three-rotor drone that takes off straight up, then flies like a plane. It flies in the PX4 simulator first.
  • The arm had six printable wrist camera mounts, and none of them worked in ROS 2.
  • I worked out exactly where the camera sits from the bolt holes in the official CAD, instead of guessing by eye.
  • One command opens the arm in Gazebo, sweeps it around and streams what the wrist camera sees.
Finished and publishedLeRobot wrist cameraA ROS 2 simulation for a wrist camera on the SO-101 robot arm, so the arm can see what it grabs.

Get in touch

The quickest way to reach me is email, at [email protected]. You can also find me on LinkedIn and GitHub, or send a message with the form.

  • Work I enjoy most: online and multiplayer code, game backends, and the tools that test them
  • Ways of working: on-site, hybrid or remote, and I'm happy to relocate
  • Time zone: Pakistan (UTC+5)
  • English: IELTS Academic 7.5

Write to me

Send me a message and I'll reply by email. Studios, recruiters and players are all welcome.